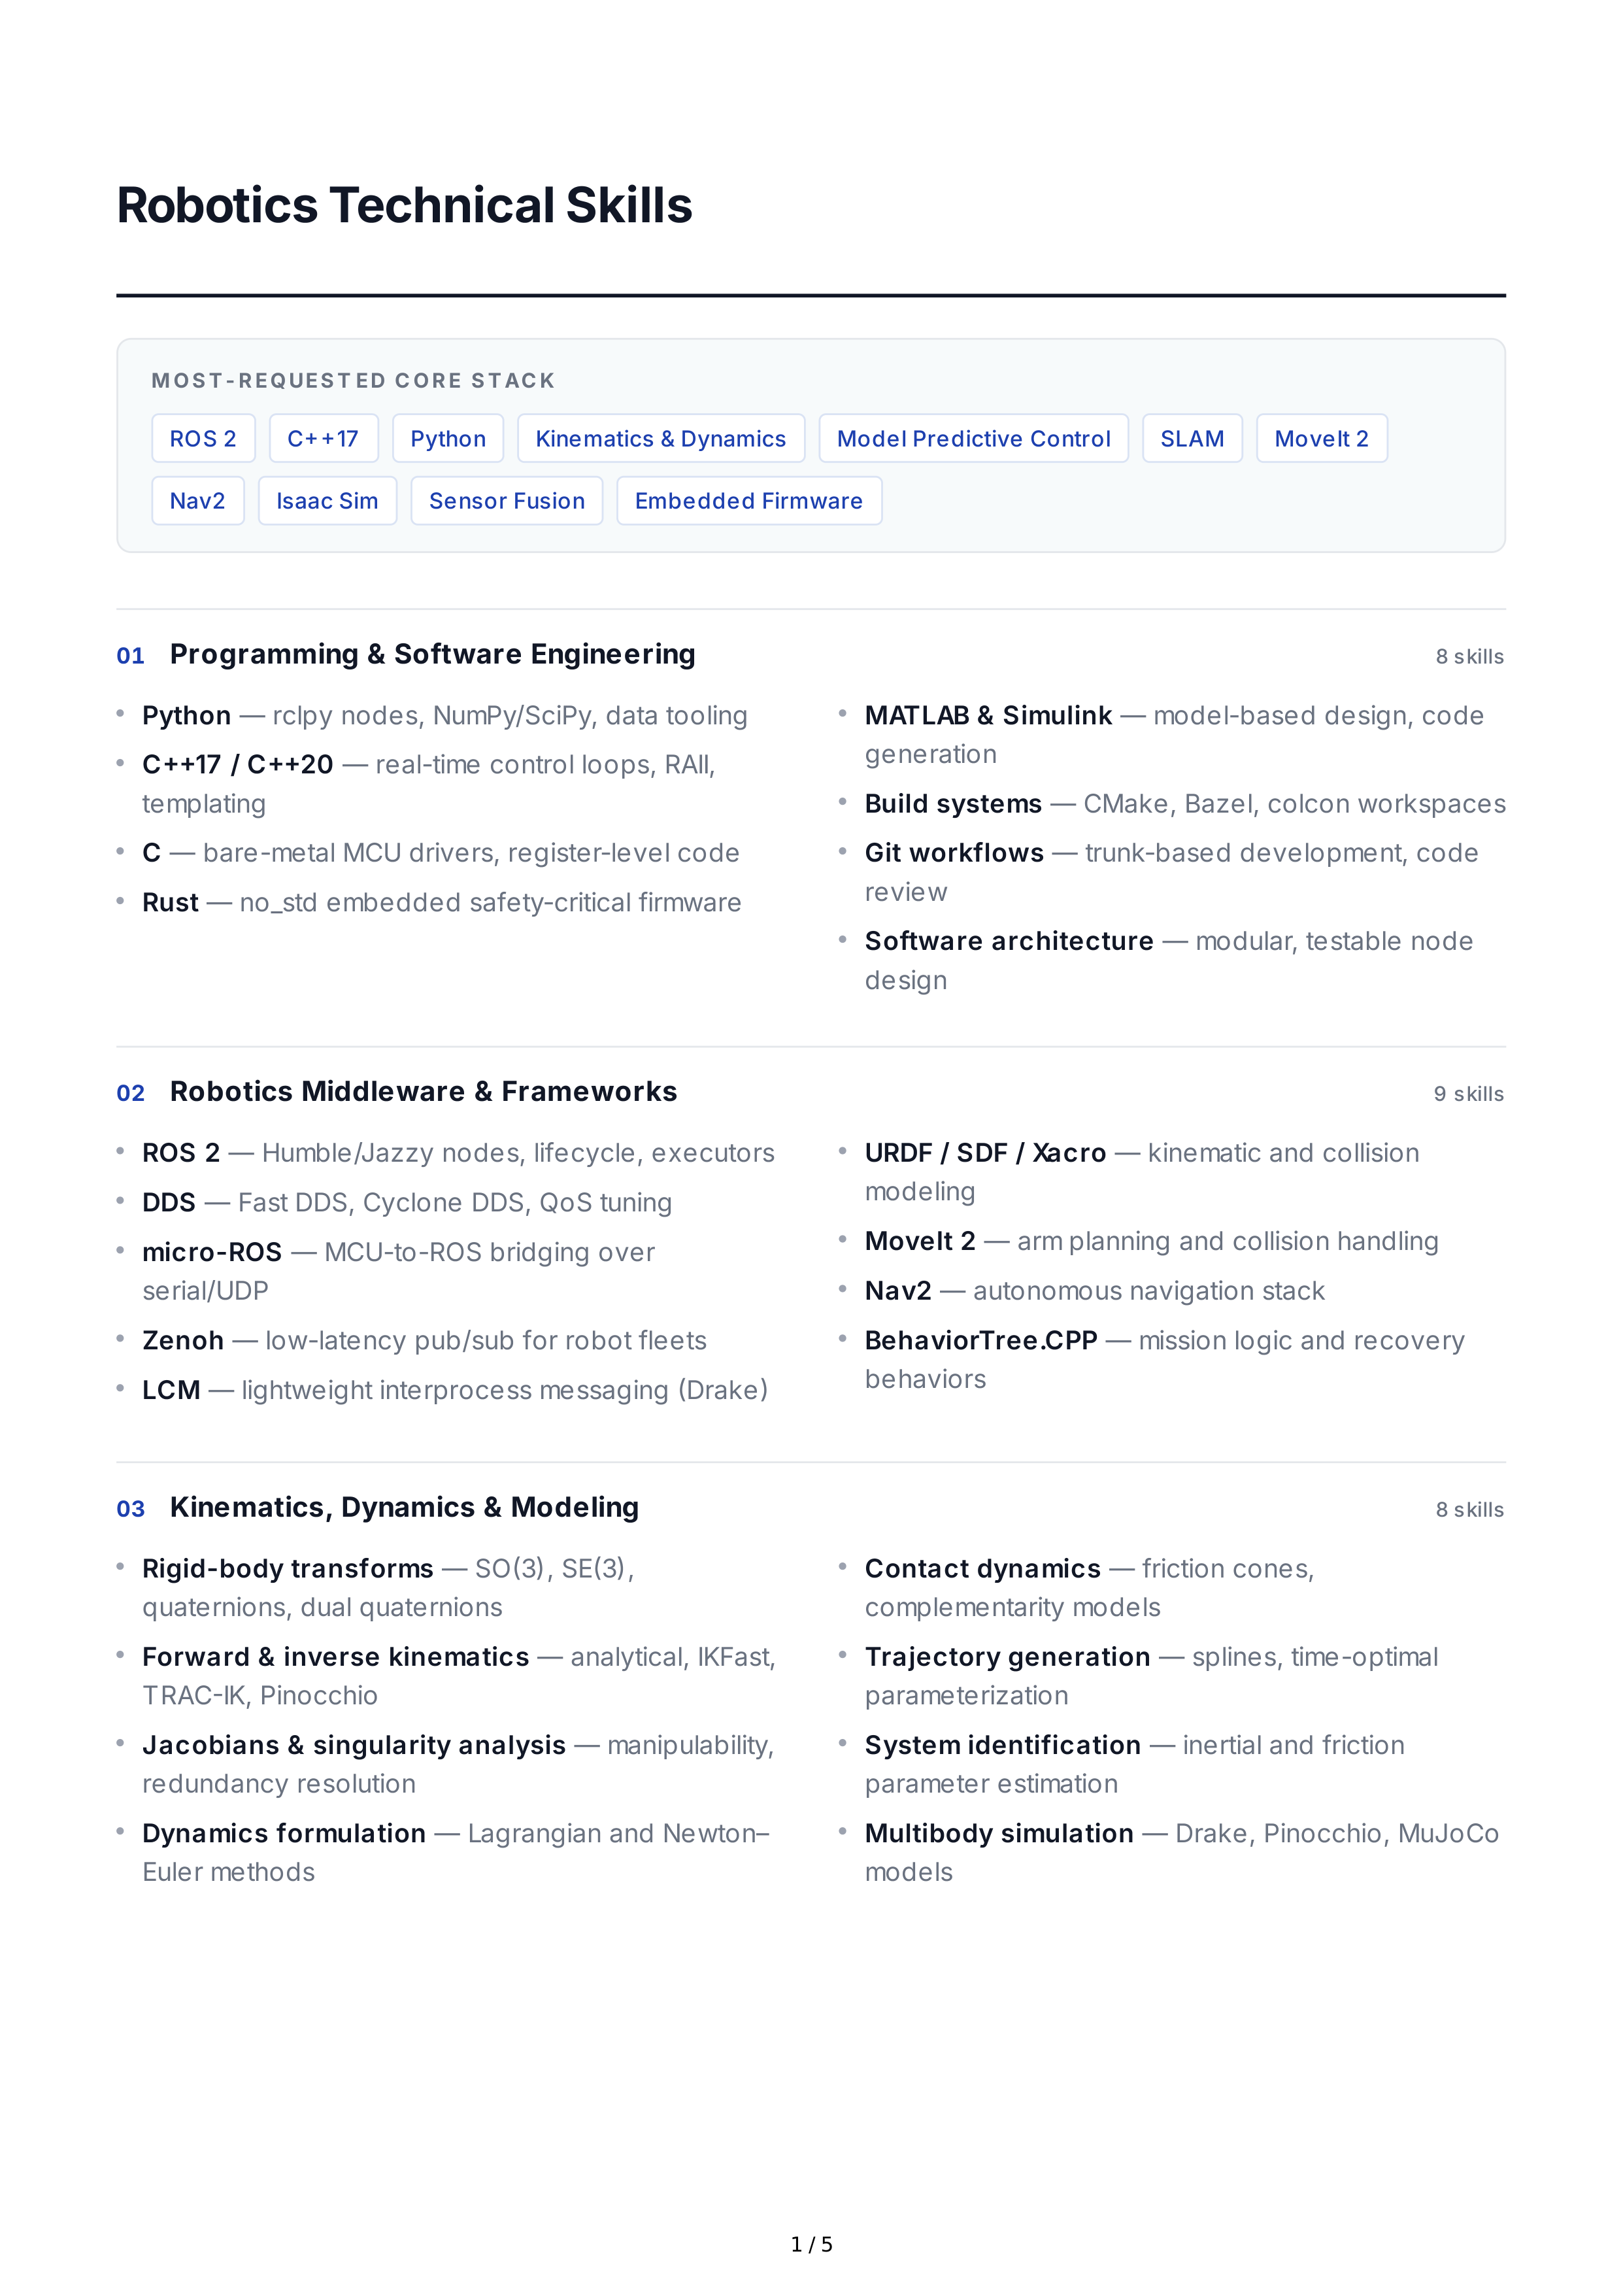
Robotics
Technical
Skills
M OS T
-
R EQUES T ED
C OR E
S T AC K
ROS
2
C
++17
Python
Kinematics
&
Dynamics
Model
Predictive
Control
SLAM
MoveIt
2
Nav
2
Isaac
Sim
Sensor
Fusion
Embedded
Firmware
01
Programming
&
Software
Engineering
8
skills
02
Robotics
Middleware
&
Frameworks
9
skills
03
Kinematics
,
Dynamics
&
Modeling
8
skills
Python
—
rclpy
nodes
,
NumPy
/
SciPy
,
data
tooling
C
++17 /
C
++20
—
real
-
time
control
loops
,
RAII
,
templating
C
—
bare
-
metal
MCU
drivers
,
register
-
level
code
Rust
—
no
_
std
embedded
safety
-
critical
firmware
MATLAB
&
Simulink
—
model
-
based
design
,
code
generation
Build
systems
—
CMake
,
Bazel
,
colcon
workspaces
Git
workflows
—
trunk
-
based
development
,
code
review
Software
architecture
—
modular
,
testable
node
design
ROS
2
—
Humble
/
Jazzy
nodes
,
lifecycle
,
executors
DDS
—
Fast
DDS
,
Cyclone
DDS
,
QoS
tuning
micro
-
ROS
—
MCU
-
to
-
ROS
bridging
over
serial
/
UDP
Zenoh
—
low
-
latency
pub
/
sub
for
robot
fleets
LCM
—
lightweight
interprocess
messaging
(
Drake
)
URDF
/
SDF
/
Xacro
—
kinematic
and
collision
modeling
MoveIt
2
—
arm
planning
and
collision
handling
Nav
2
—
autonomous
navigation
stack
BehaviorTree
.
CPP
—
mission
logic
and
recovery
behaviors
Rigid
-
body
transforms
—
SO
(3),
SE
(3),
quaternions
,
dual
quaternions
Forward
&
inverse
kinematics
—
analytical
,
IKFast
,
TRAC
-
IK
,
Pinocchio
Jacobians
&
singularity
analysis
—
manipulability
,
redundancy
resolution
Dynamics
formulation
—
Lagrangian
and
Newton
–
Euler
methods
Contact
dynamics
—
friction
cones
,
complementarity
models
Trajectory
generation
—
splines
,
time
-
optimal
parameterization
System
identification
—
inertial
and
friction
parameter
estimation
Multibody
simulation
—
Drake
,
Pinocchio
,
MuJoCo
models
1 / 5
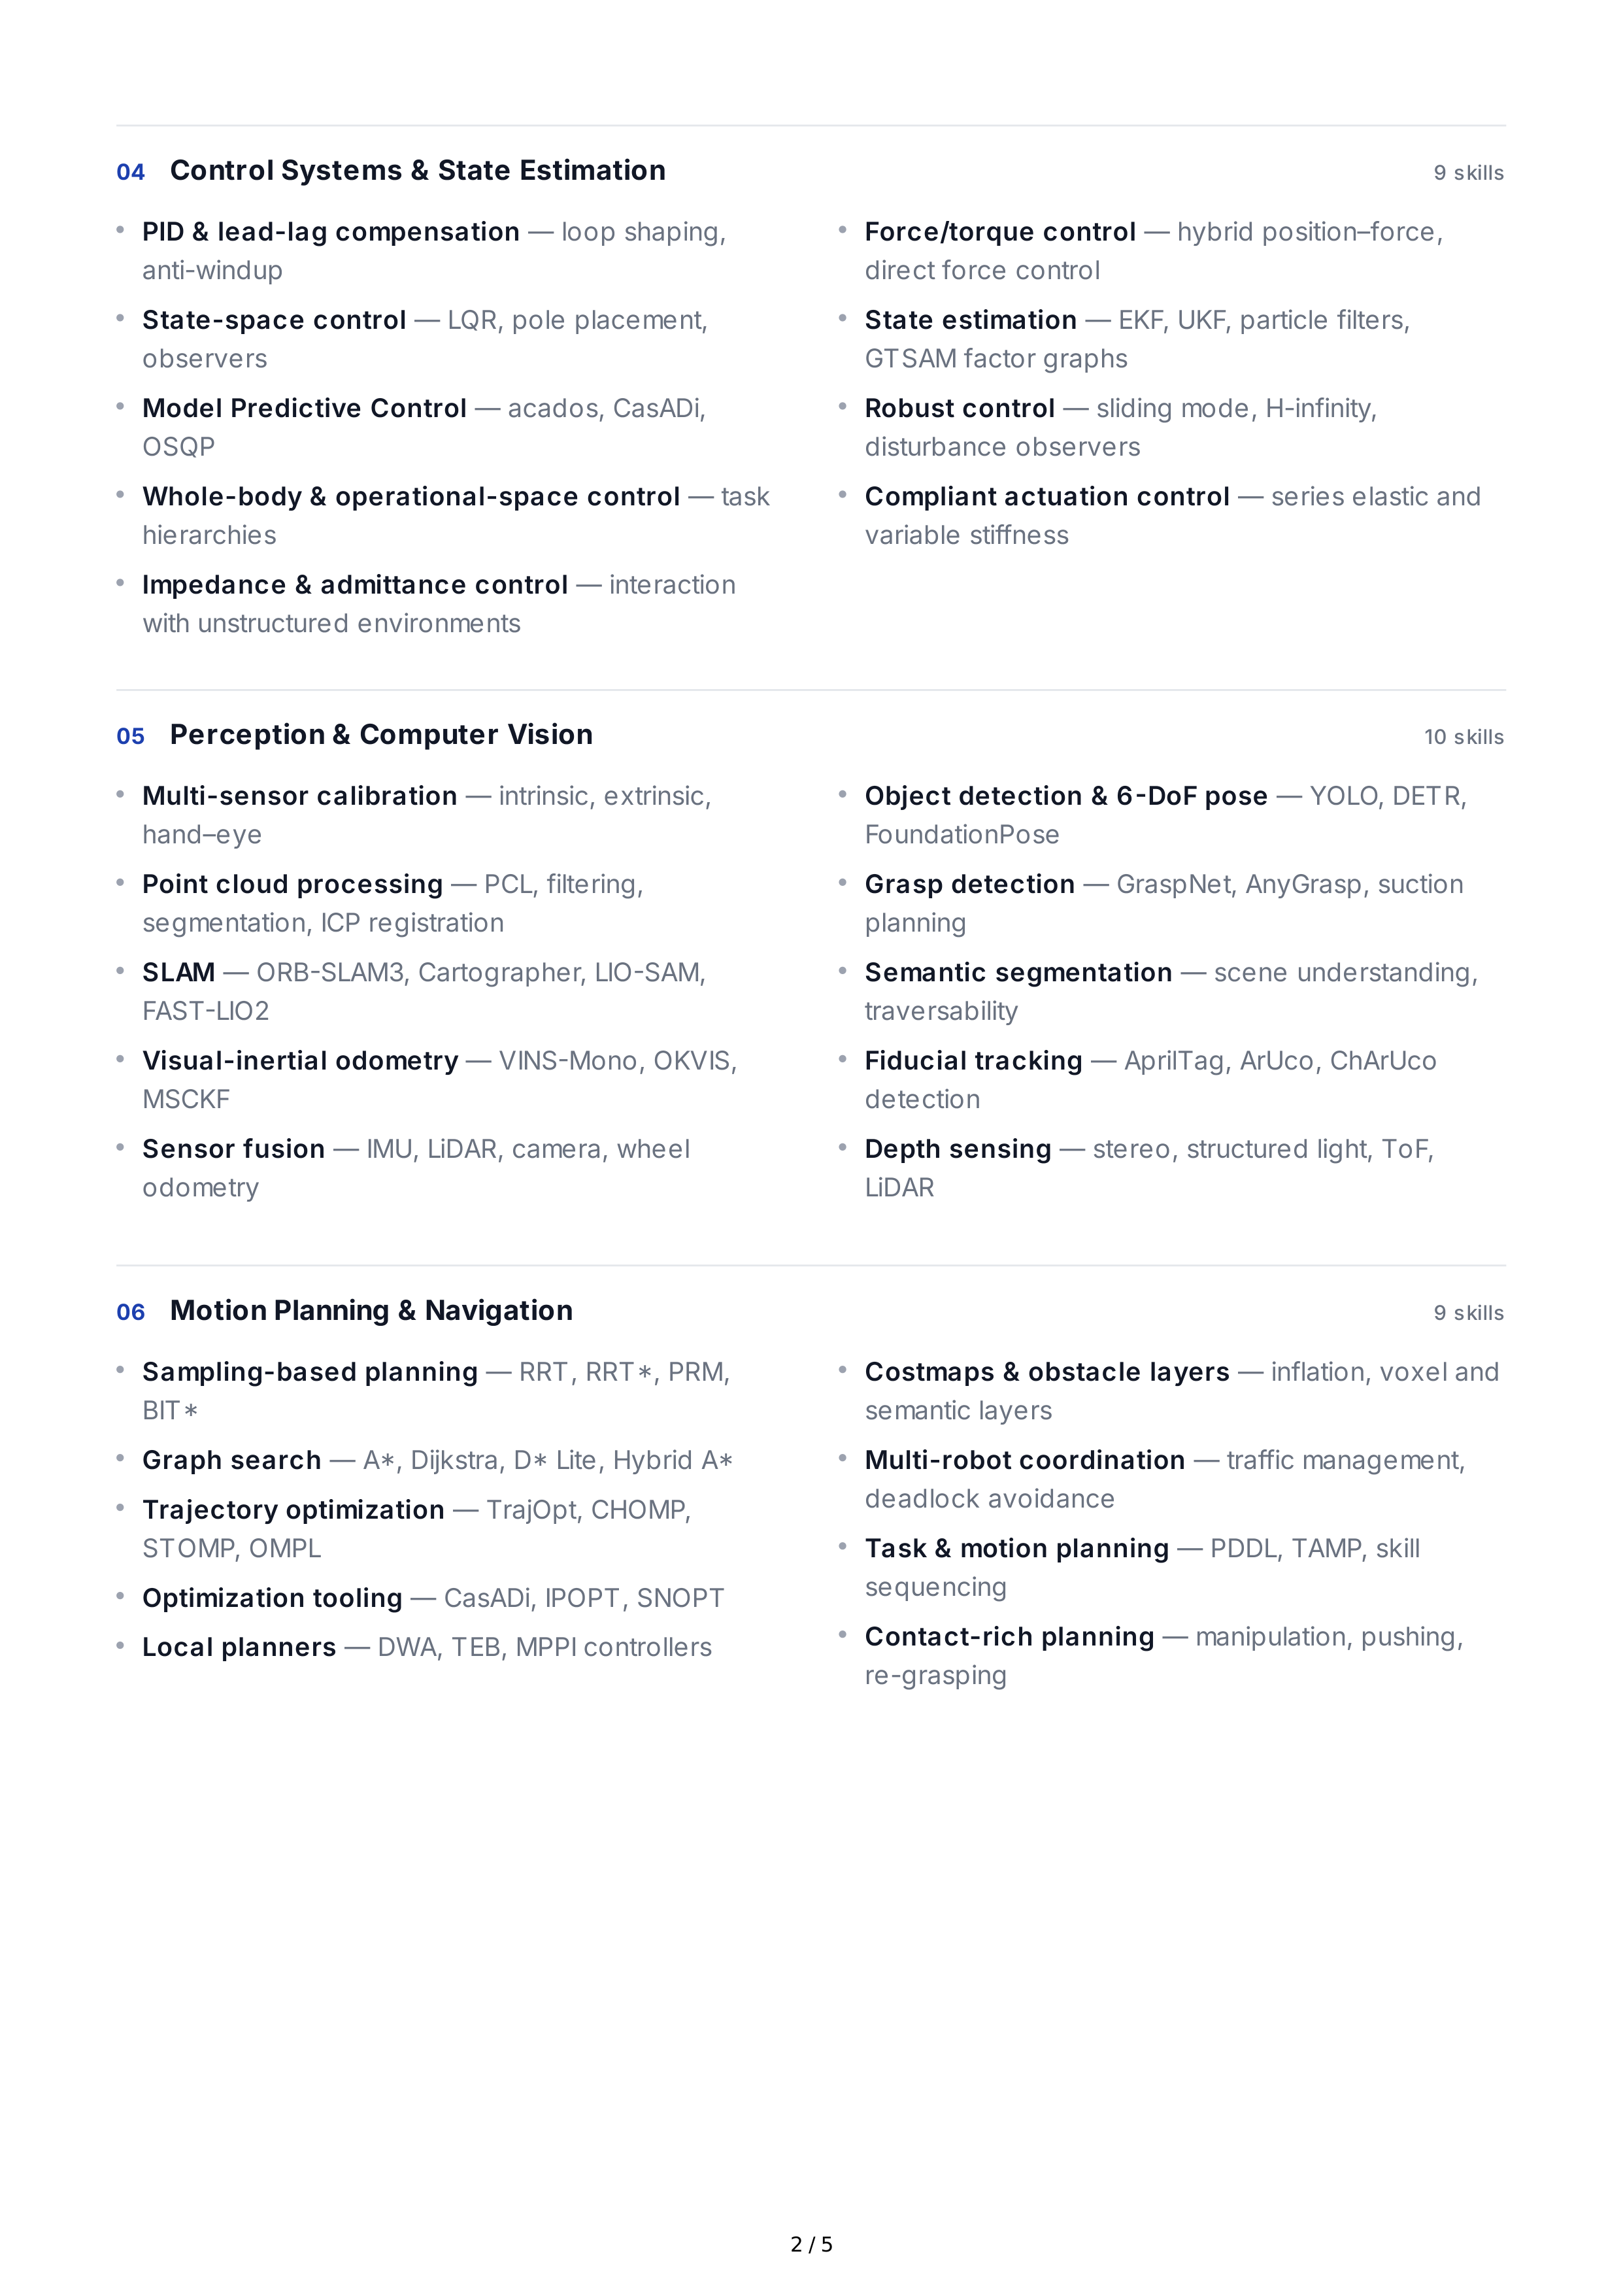
04
Control
Systems
&
State
Estimation
9
skills
05
Perception
&
Computer
Vision
10
skills
06
Motion
Planning
&
Navigation
9
skills
PID
&
lead
-
lag
compensation
—
loop
shaping
,
anti
-
windup
State
-
space
control
—
LQR
,
pole
placement
,
observers
Model
Predictive
Control
—
acados
,
CasADi
,
OSQP
Whole
-
body
&
operational
-
space
control
—
task
hierarchies
Impedance
&
admittance
control
—
interaction
with
unstructured
environments
Force
/
torque
control
—
hybrid
position
–
force
,
direct
force
control
State
estimation
—
EKF
,
UKF
,
particle
filters
,
GTSAM
factor
graphs
Robust
control
—
sliding
mode
,
H
-
infinity
,
disturbance
observers
Compliant
actuation
control
—
series
elastic
and
variable
stiffness
Multi
-
sensor
calibration
—
intrinsic
,
extrinsic
,
hand
–
eye
Point
cloud
processing
—
PCL
,
filtering
,
segmentation
,
ICP
registration
SLAM
—
ORB
-
SLAM
3,
Cartographer
,
LIO
-
SAM
,
FAST
-
LIO
2
Visual
-
inertial
odometry
—
VINS
-
Mono
,
OKVIS
,
MSCKF
Sensor
fusion
—
IMU
,
LiDAR
,
camera
,
wheel
odometry
Object
detection
& 6-
DoF
pose
—
YOLO
,
DETR
,
FoundationPose
Grasp
detection
—
GraspNet
,
AnyGrasp
,
suction
planning
Semantic
segmentation
—
scene
understanding
,
traversability
Fiducial
tracking
—
AprilTag
,
ArUco
,
ChArUco
detection
Depth
sensing
—
stereo
,
structured
light
,
ToF
,
LiDAR
Sampling
-
based
planning
—
RRT
,
RRT
*,
PRM
,
BIT
*
Graph
search
—
A
*,
Dijkstra
,
D
*
Lite
,
Hybrid
A
*
Trajectory
optimization
—
TrajOpt
,
CHOMP
,
STOMP
,
OMPL
Optimization
tooling
—
CasADi
,
IPOPT
,
SNOPT
Local
planners
—
DWA
,
TEB
,
MPPI
controllers
Costmaps
&
obstacle
layers
—
inflation
,
voxel
and
semantic
layers
Multi
-
robot
coordination
—
traffic
management
,
deadlock
avoidance
Task
&
motion
planning
—
PDDL
,
TAMP
,
skill
sequencing
Contact
-
rich
planning
—
manipulation
,
pushing
,
re
-
grasping
2 / 5
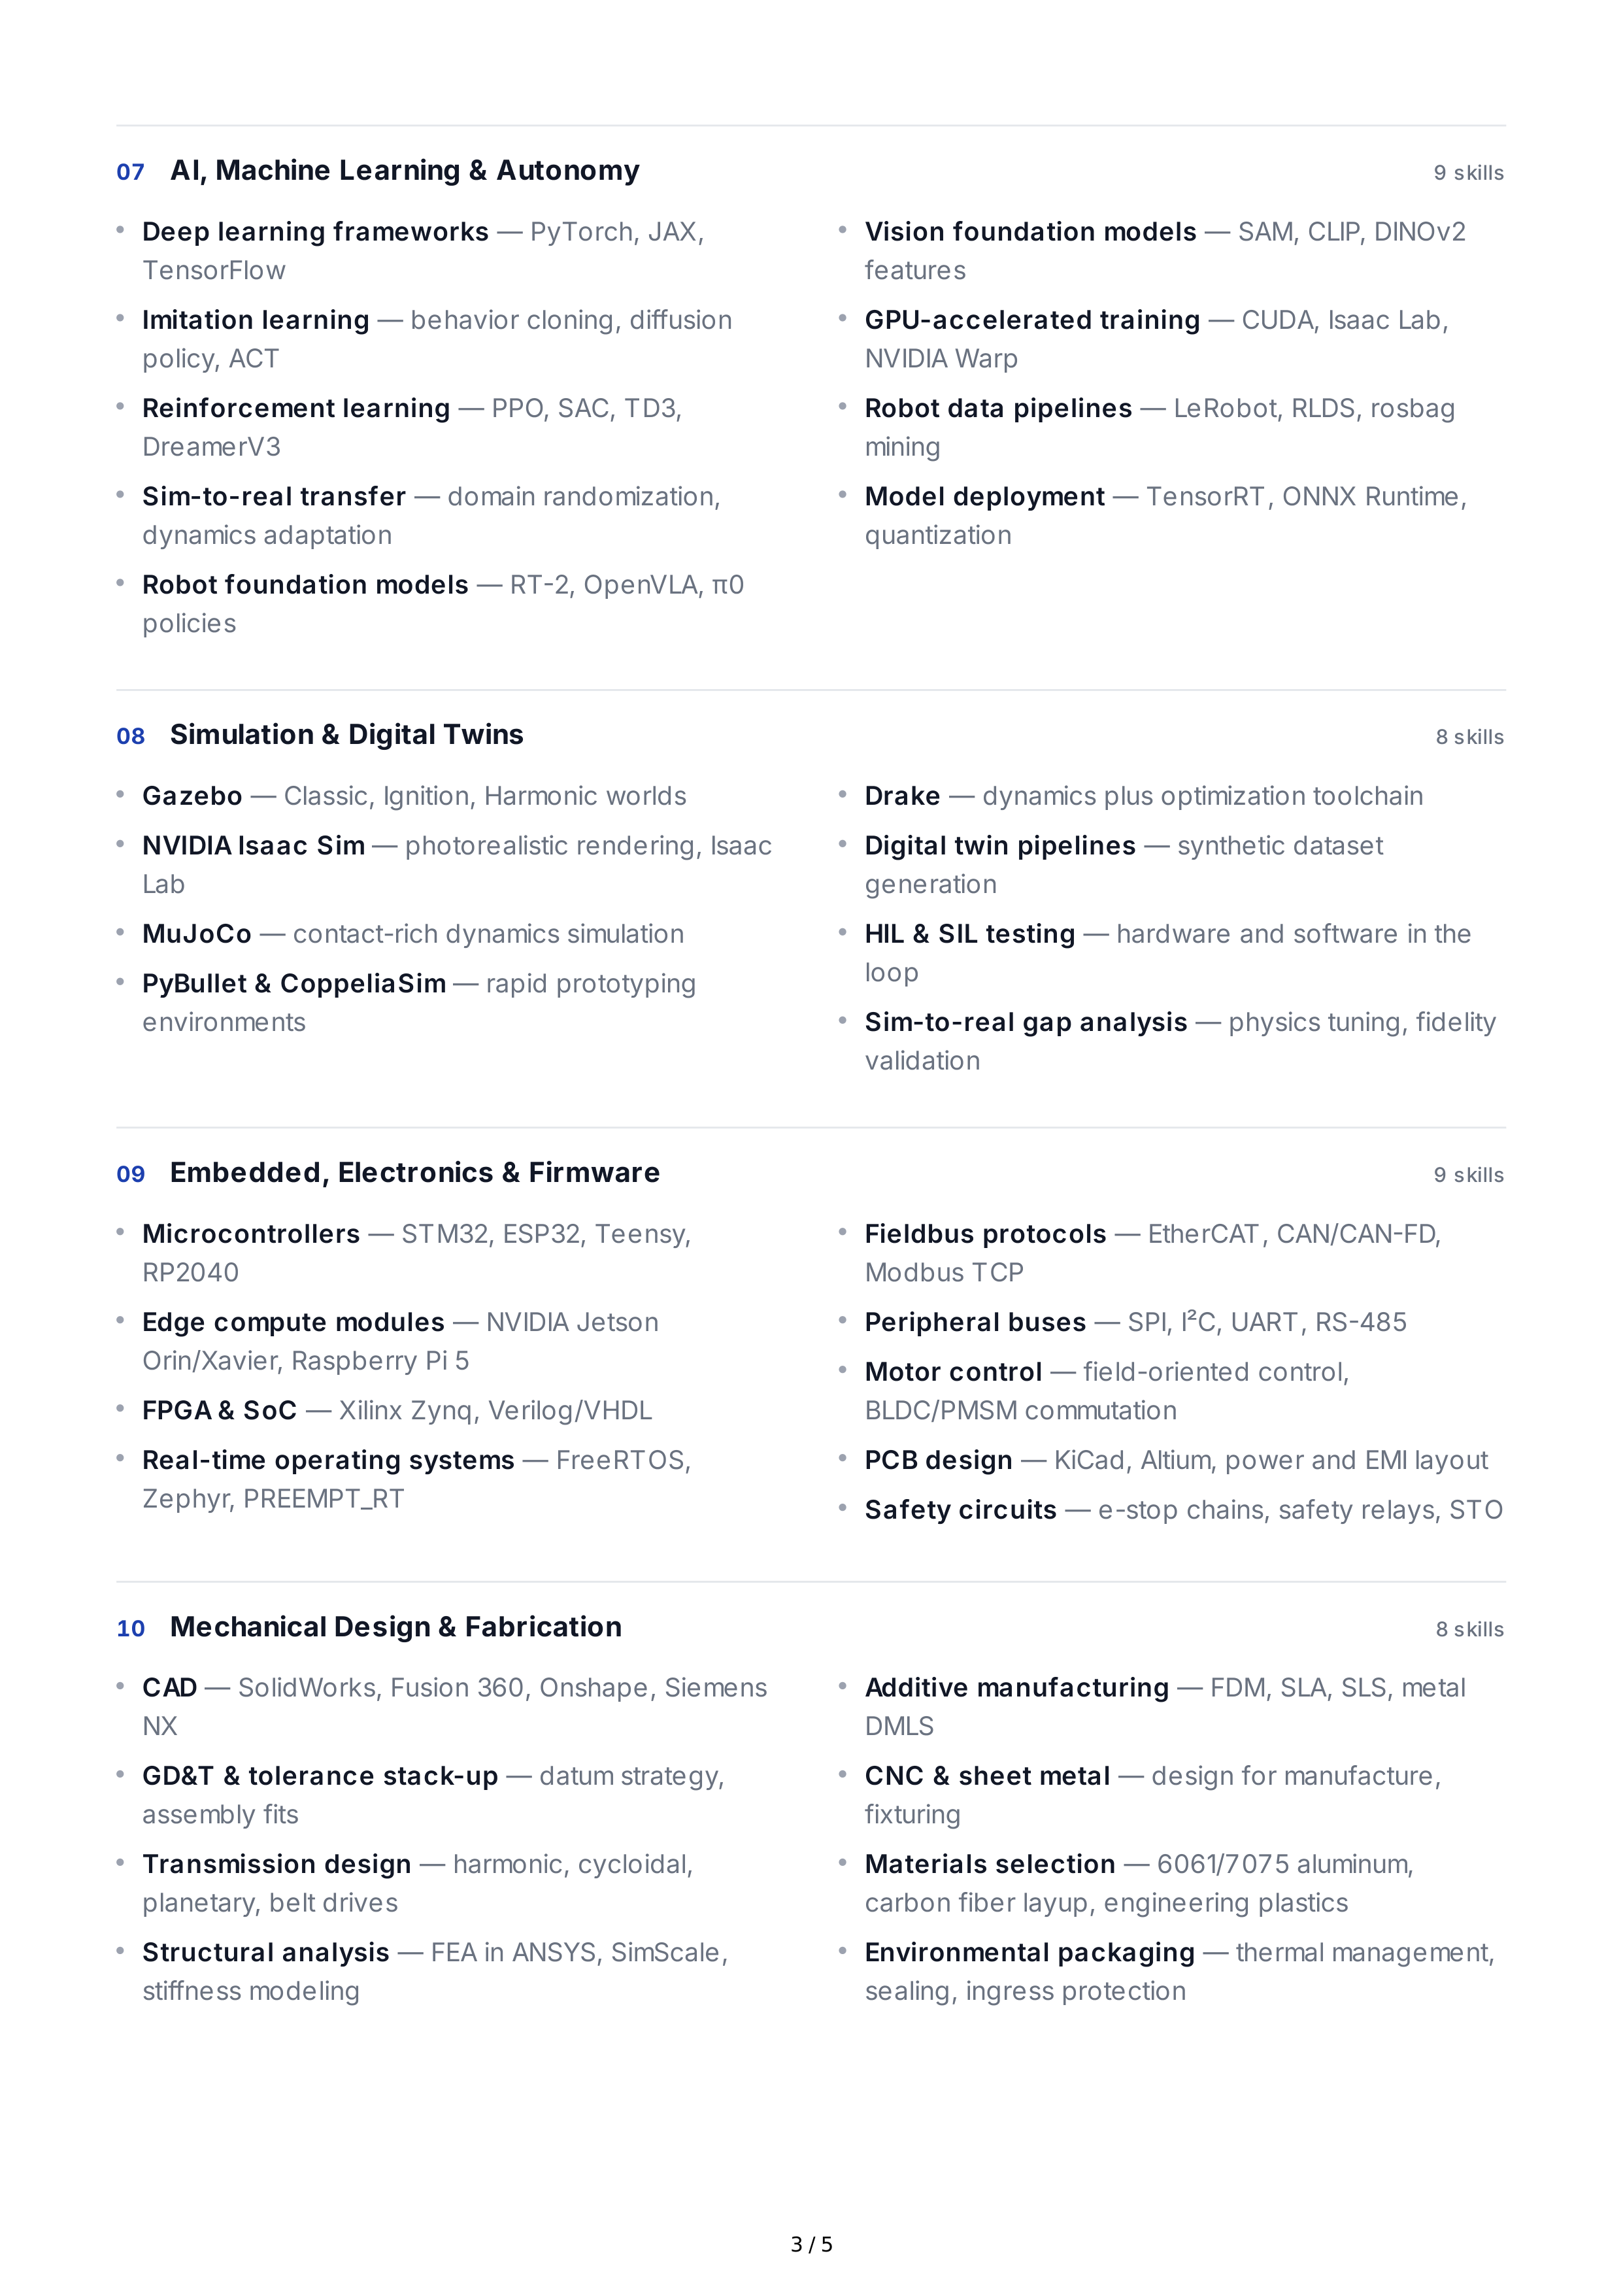
07
AI
,
Machine
Learning
&
Autonomy
9
skills
08
Simulation
&
Digital
Twins
8
skills
09
Embedded
,
Electronics
&
Firmware
9
skills
10
Mechanical
Design
&
Fabrication
8
skills
Deep
learning
frameworks
—
PyTorch
,
JAX
,
TensorFlow
Imitation
learning
—
behavior
cloning
,
diffusion
policy
,
ACT
Reinforcement
learning
—
PPO
,
SAC
,
TD
3,
DreamerV
3
Sim
-
to
-
real
transfer
—
domain
randomization
,
dynamics
adaptation
Robot
foundation
models
—
RT
-2,
OpenVLA
,
π
0
policies
Vision
foundation
models
—
SAM
,
CLIP
,
DINOv
2
features
GPU
-
accelerated
training
—
CUDA
,
Isaac
Lab
,
NVIDIA
Warp
Robot
data
pipelines
—
LeRobot
,
RLDS
,
rosbag
mining
Model
deployment
—
TensorRT
,
ONNX
Runtime
,
quantization
Gazebo
—
Classic
,
Ignition
,
Harmonic
worlds
NVIDIA
Isaac
Sim
—
photorealistic
rendering
,
Isaac
Lab
MuJoCo
—
contact
-
rich
dynamics
simulation
PyBullet
&
CoppeliaSim
—
rapid
prototyping
environments
Drake
—
dynamics
plus
optimization
toolchain
Digital
twin
pipelines
—
synthetic
dataset
generation
HIL
&
SIL
testing
—
hardware
and
software
in
the
loop
Sim
-
to
-
real
gap
analysis
—
physics
tuning
,
fidelity
validation
Microcontrollers
—
STM
32,
ESP
32,
Teensy
,
RP
2040
Edge
compute
modules
—
NVIDIA
Jetson
Orin
/
Xavier
,
Raspberry
Pi
5
FPGA
&
SoC
—
Xilinx
Zynq
,
Verilog
/
VHDL
Real
-
time
operating
systems
—
FreeRTOS
,
Zephyr
,
PREEMPT
_
RT
Fieldbus
protocols
—
EtherCAT
,
CAN
/
CAN
-
FD
,
Modbus
TCP
Peripheral
buses
—
SPI
,
I
²
C
,
UART
,
RS
-485
Motor
control
—
field
-
oriented
control
,
BLDC
/
PMSM
commutation
PCB
design
—
KiCad
,
Altium
,
power
and
EMI
layout
Safety
circuits
—
e
-
stop
chains
,
safety
relays
,
STO
CAD
—
SolidWorks
,
Fusion
360,
Onshape
,
Siemens
NX
GD
&
T
&
tolerance
stack
-
up
—
datum
strategy
,
assembly
fits
Transmission
design
—
harmonic
,
cycloidal
,
planetary
,
belt
drives
Structural
analysis
—
FEA
in
ANSYS
,
SimScale
,
stiffness
modeling
Additive
manufacturing
—
FDM
,
SLA
,
SLS
,
metal
DMLS
CNC
&
sheet
metal
—
design
for
manufacture
,
fixturing
Materials
selection
— 6061/7075
aluminum
,
carbon
fiber
layup
,
engineering
plastics
Environmental
packaging
—
thermal
management
,
sealing
,
ingress
protection
3 / 5
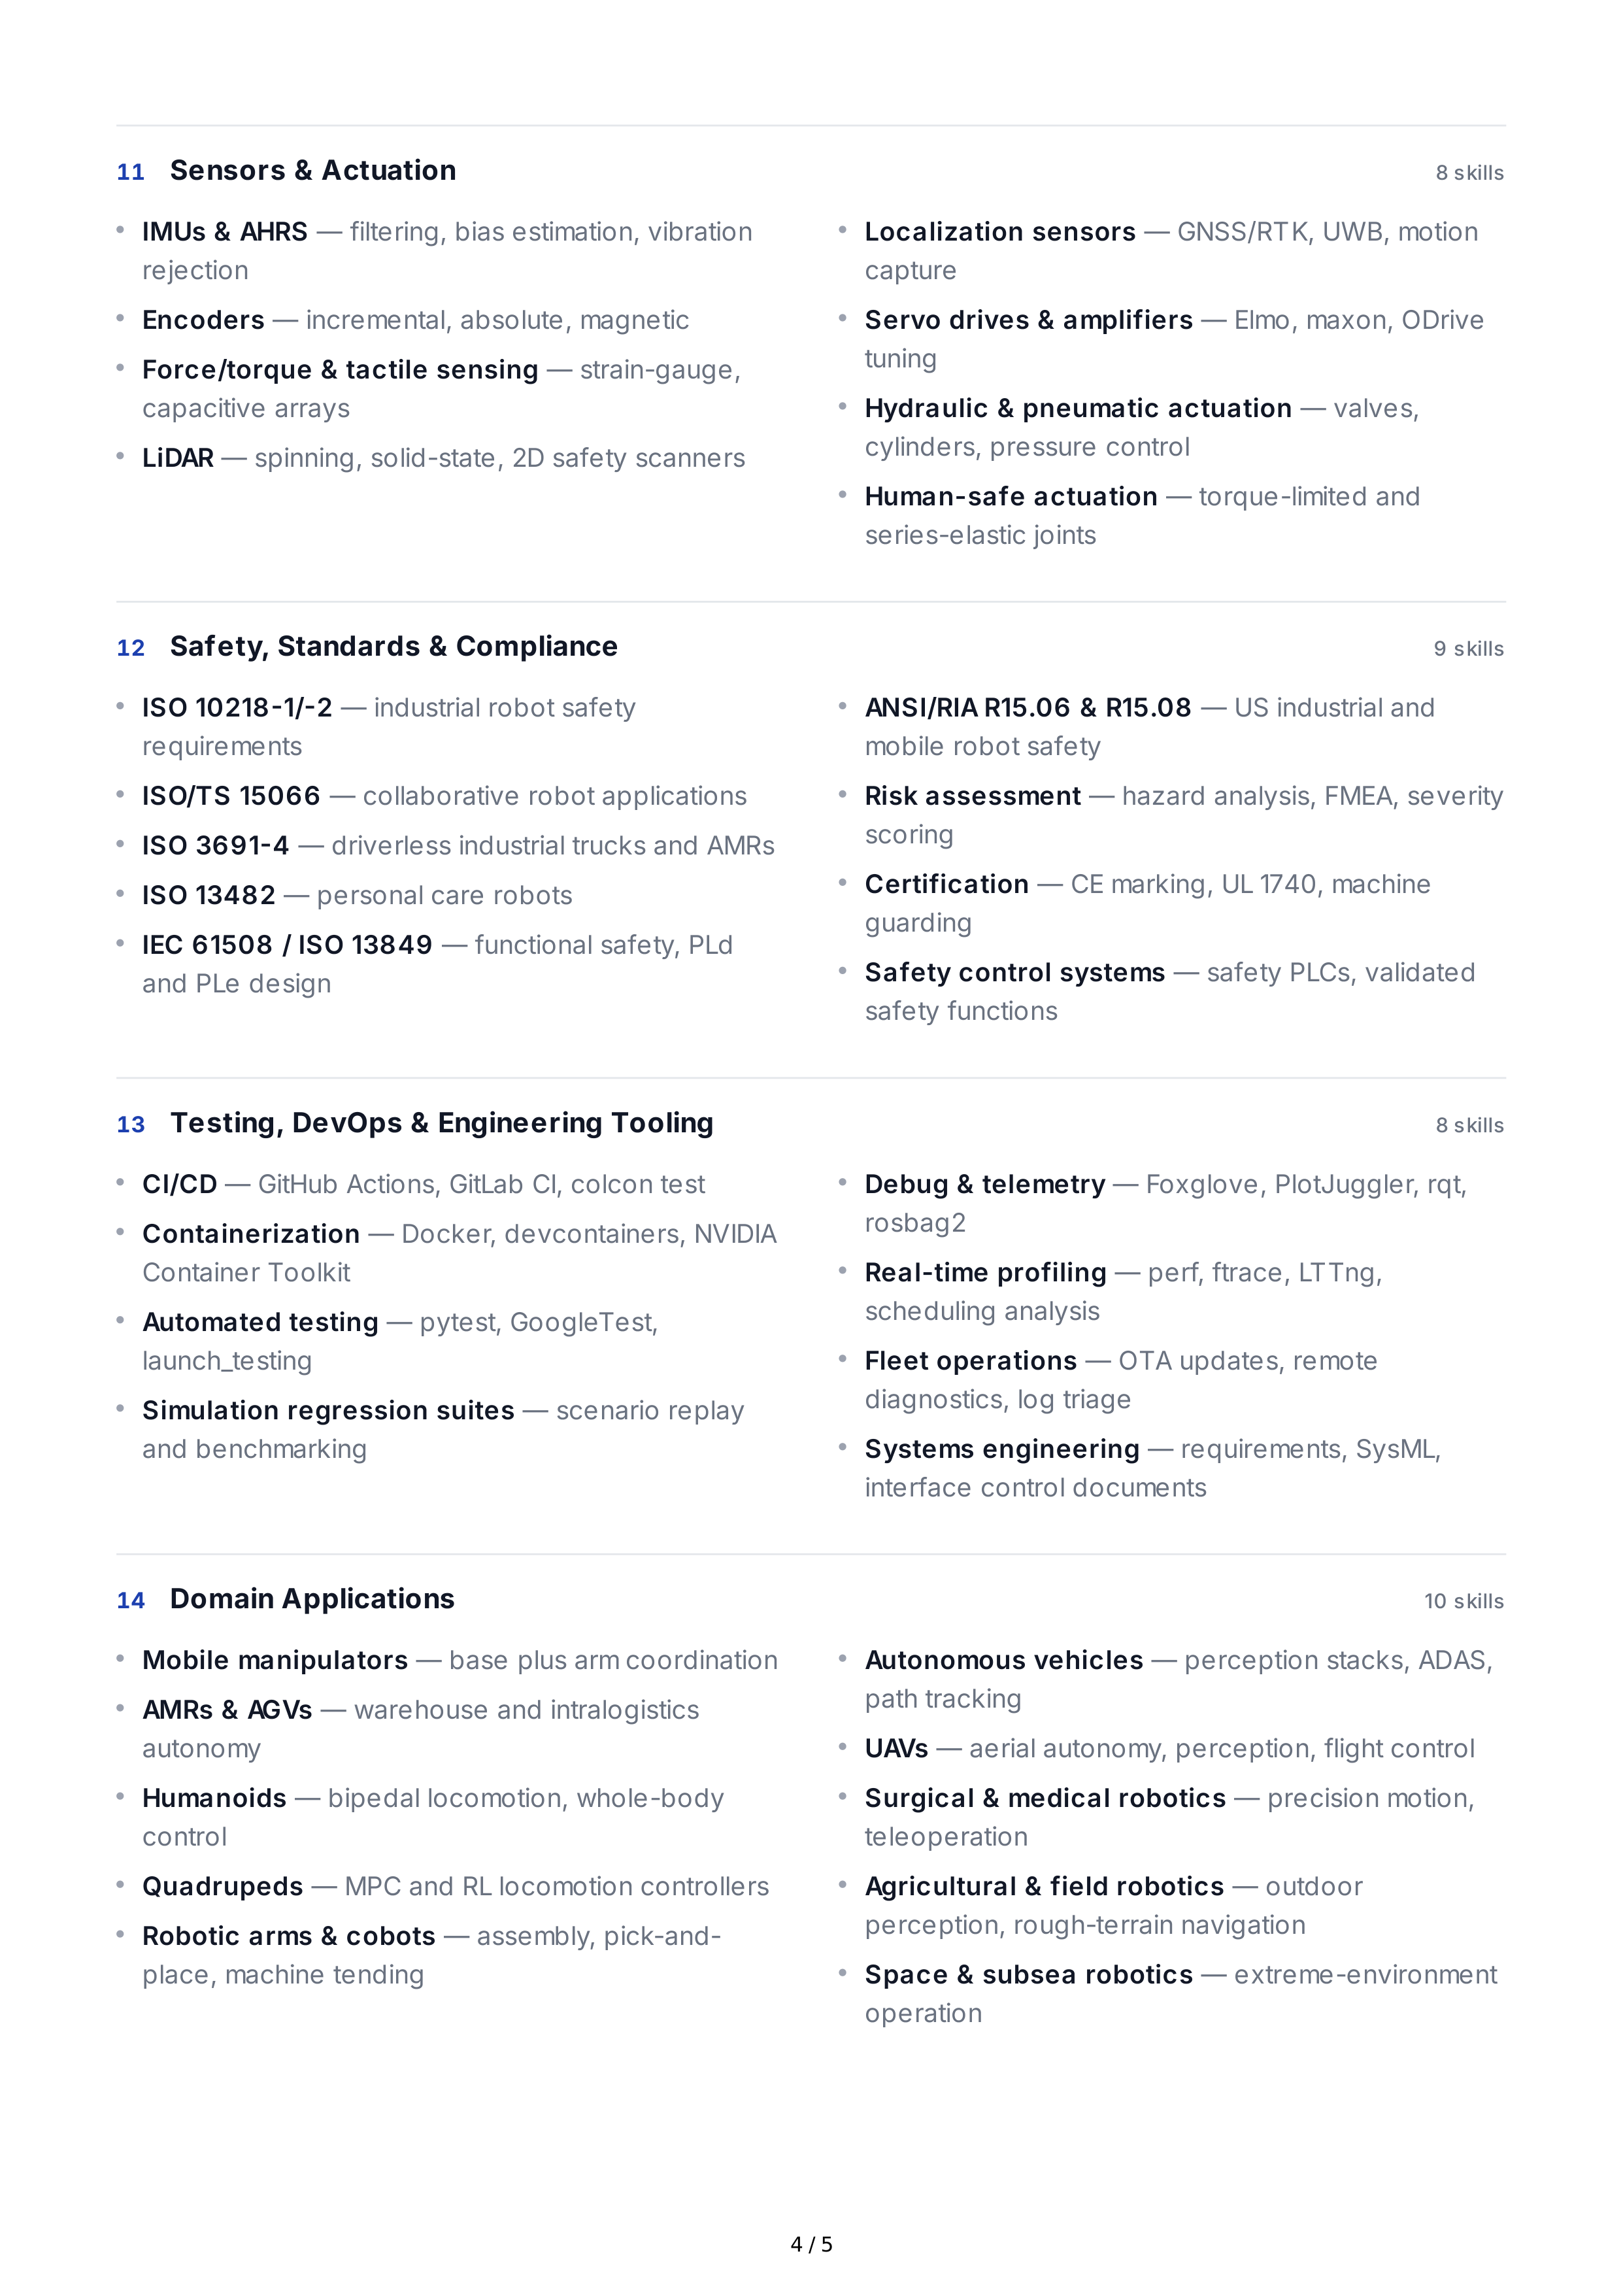
11
Sensors
&
Actuation
8
skills
12
Safety
,
Standards
&
Compliance
9
skills
13
Testing
,
DevOps
&
Engineering
Tooling
8
skills
14
Domain
Applications
10
skills
IMUs
&
AHRS
—
filtering
,
bias
estimation
,
vibration
rejection
Encoders
—
incremental
,
absolute
,
magnetic
Force
/
torque
&
tactile
sensing
—
strain
-
gauge
,
capacitive
arrays
LiDAR
—
spinning
,
solid
-
state
, 2
D
safety
scanners
Localization
sensors
—
GNSS
/
RTK
,
UWB
,
motion
capture
Servo
drives
&
amplifiers
—
Elmo
,
maxon
,
ODrive
tuning
Hydraulic
&
pneumatic
actuation
—
valves
,
cylinders
,
pressure
control
Human
-
safe
actuation
—
torque
-
limited
and
series
-
elastic
joints
ISO
10218-1/-2
—
industrial
robot
safety
requirements
ISO
/
TS
15066
—
collaborative
robot
applications
ISO
3691-4
—
driverless
industrial
trucks
and
AMRs
ISO
13482
—
personal
care
robots
IEC
61508 /
ISO
13849
—
functional
safety
,
PLd
and
PLe
design
ANSI
/
RIA
R
15.06 &
R
15.08
—
US
industrial
and
mobile
robot
safety
Risk
assessment
—
hazard
analysis
,
FMEA
,
severity
scoring
Certification
—
CE
marking
,
UL
1740,
machine
guarding
Safety
control
systems
—
safety
PLCs
,
validated
safety
functions
CI
/
CD
—
GitHub
Actions
,
GitLab
CI
,
colcon
test
Containerization
—
Docker
,
devcontainers
,
NVIDIA
Container
Toolkit
Automated
testing
—
pytest
,
GoogleTest
,
launch
_
testing
Simulation
regression
suites
—
scenario
replay
and
benchmarking
Debug
&
telemetry
—
Foxglove
,
PlotJuggler
,
rqt
,
rosbag
2
Real
-
time
profiling
—
perf
,
ftrace
,
LTTng
,
scheduling
analysis
Fleet
operations
—
OTA
updates
,
remote
diagnostics
,
log
triage
Systems
engineering
—
requirements
,
SysML
,
interface
control
documents
Mobile
manipulators
—
base
plus
arm
coordination
AMRs
&
AGVs
—
warehouse
and
intralogistics
autonomy
Humanoids
—
bipedal
locomotion
,
whole
-
body
control
Quadrupeds
—
MPC
and
RL
locomotion
controllers
Robotic
arms
&
cobots
—
assembly
,
pick
-
and
-
place
,
machine
tending
Autonomous
vehicles
—
perception
stacks
,
ADAS
,
path
tracking
UAVs
—
aerial
autonomy
,
perception
,
flight
control
Surgical
&
medical
robotics
—
precision
motion
,
teleoperation
Agricultural
&
field
robotics
—
outdoor
perception
,
rough
-
terrain
navigation
Space
&
subsea
robotics
—
extreme
-
environment
operation
4 / 5
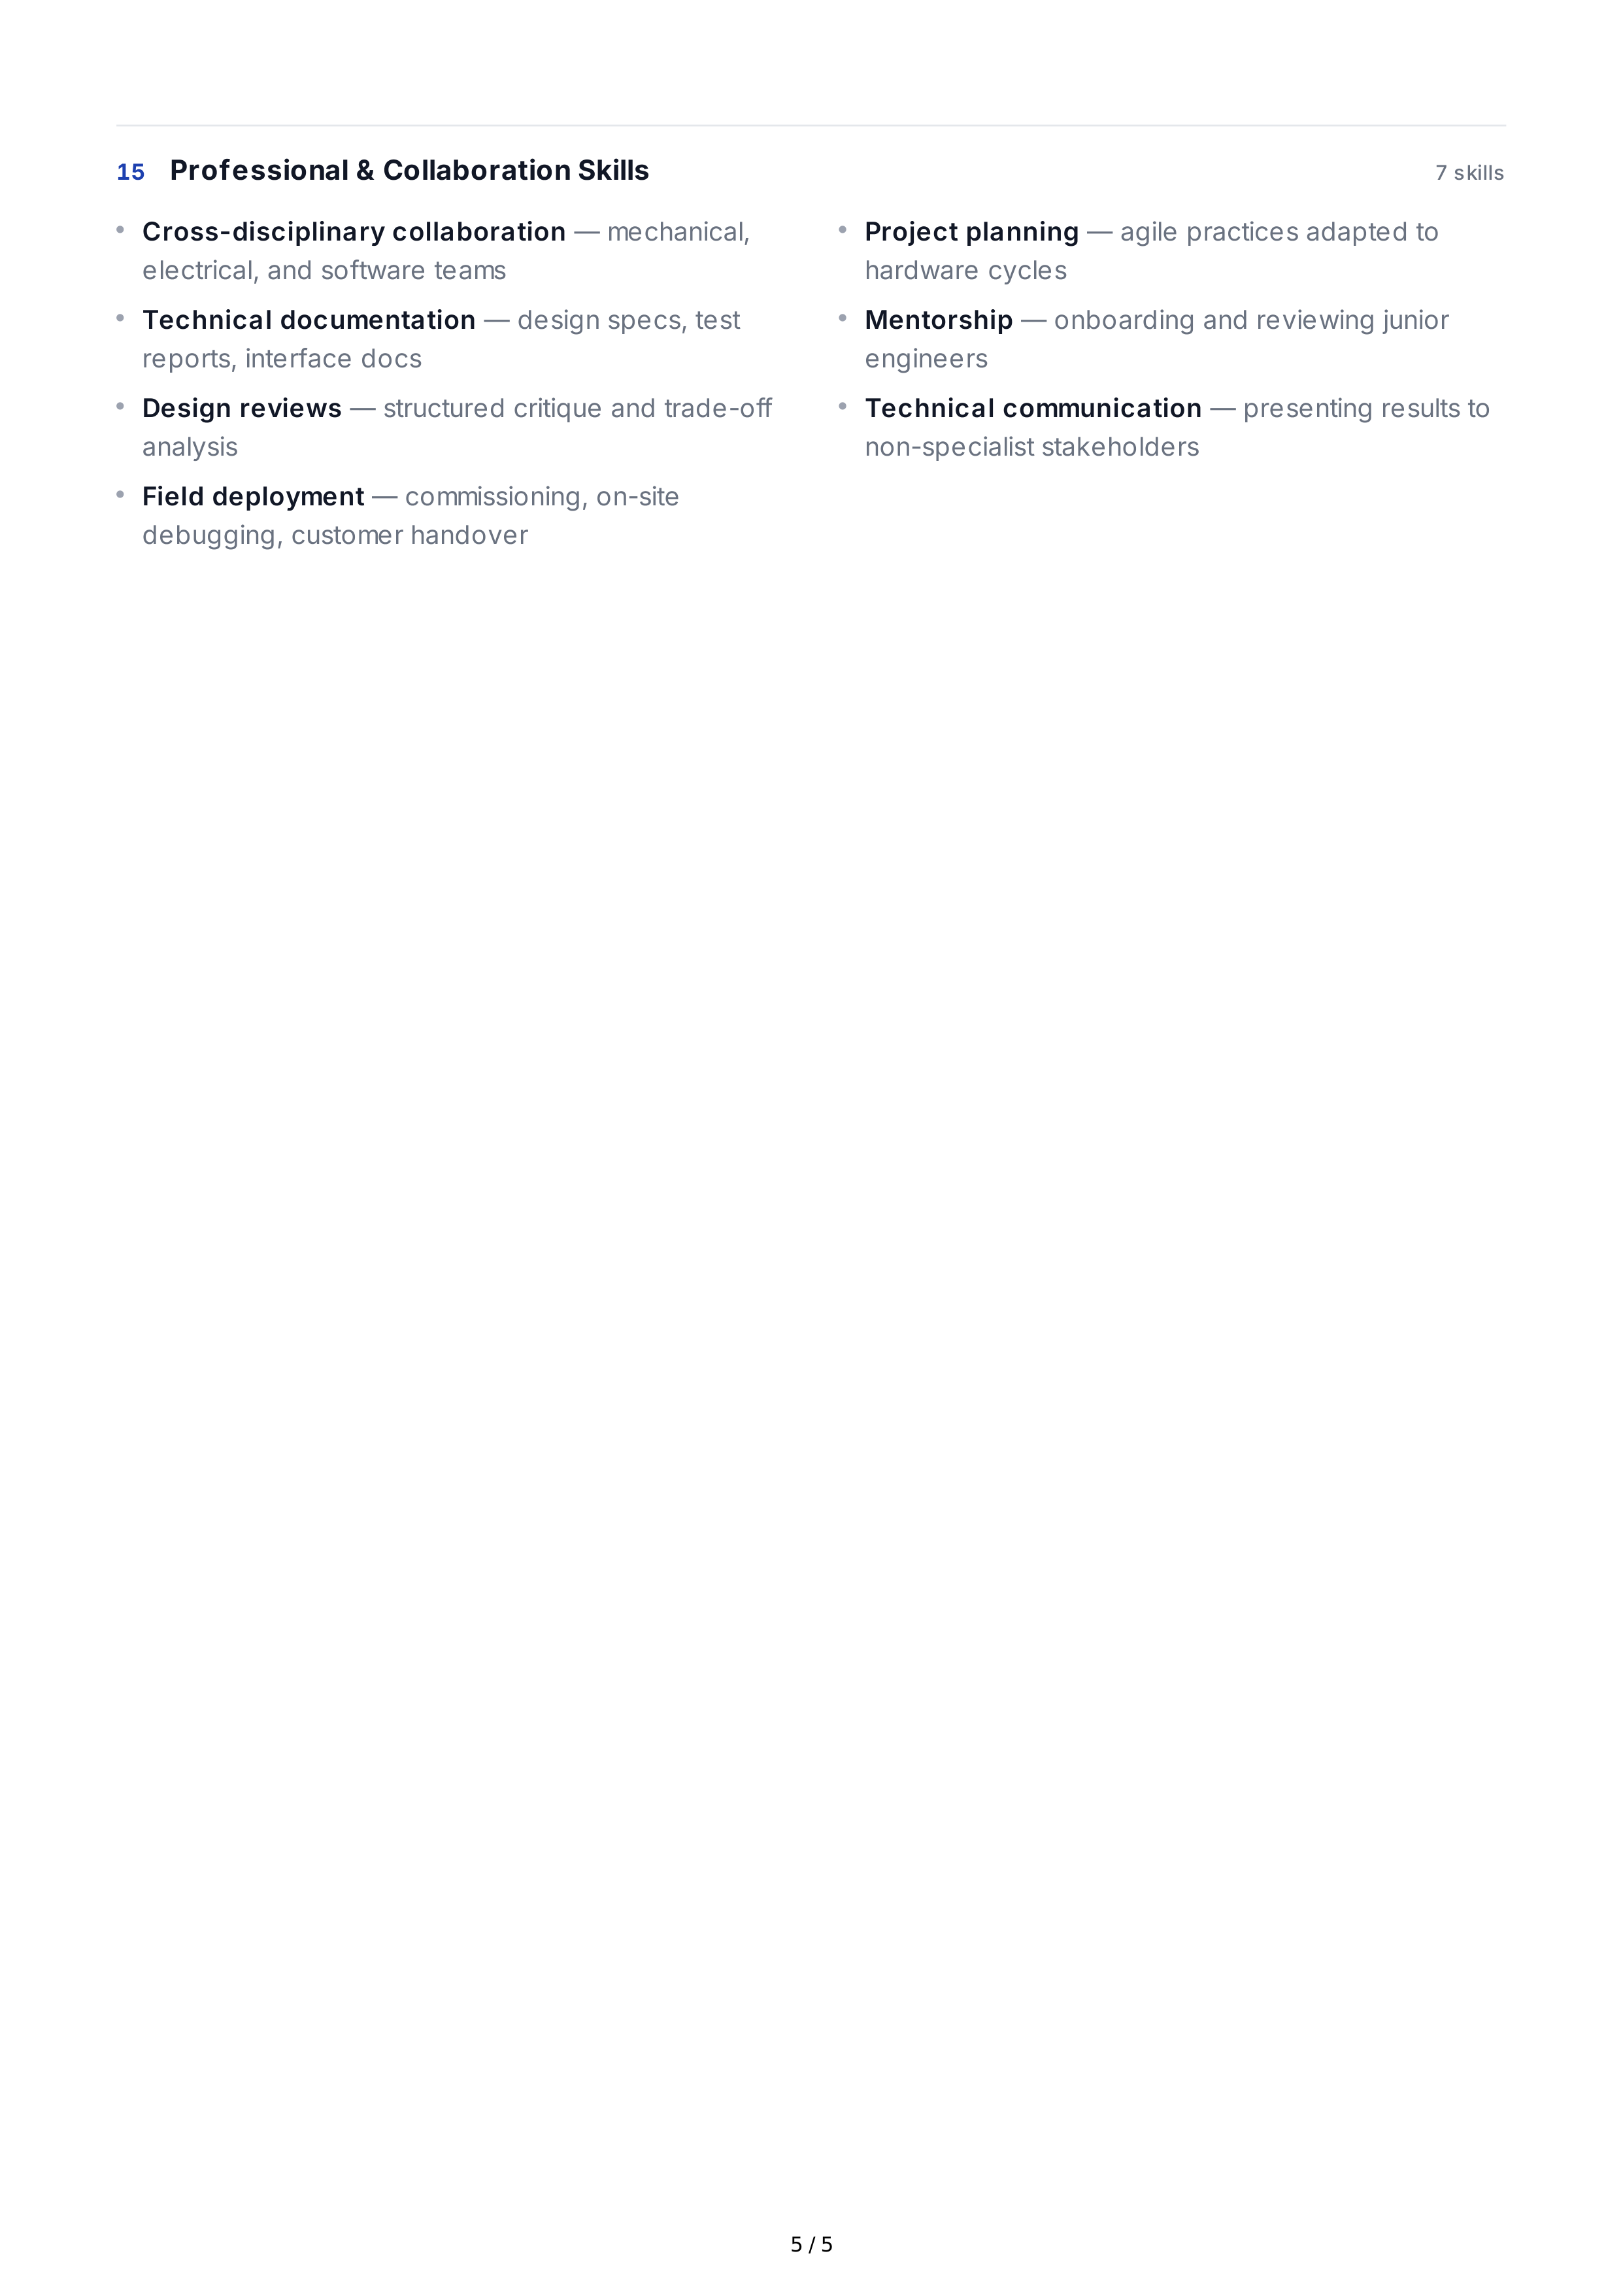
15
Professional
&
Collaboration
Skills
7
skills
Cross
-
disciplinary
collaboration
—
mechanical
,
electrical
,
and
software
teams
Technical
documentation
—
design
specs
,
test
reports
,
interface
docs
Design
reviews
—
structured
critique
and
trade
-
off
analysis
Field
deployment
—
commissioning
,
on
-
site
debugging
,
customer
handover
Project
planning
—
agile
practices
adapted
to
hardware
cycles
Mentorship
—
onboarding
and
reviewing
junior
engineers
Technical
communication
—
presenting
results
to
non
-
specialist
stakeholders
5 / 5